About Me
I am currently a Research Fellow at the National University of Singapore. My work sits at the intersection of control theory and robotics, with a particular emphasis on systems that are nonlinear, underactuated, and challenging to deploy reliably in real-world environments.
My primary interests include aerial robotic systems, robust nonlinear control, and the full path from mathematical design to experimental deployment. Along the way, I have worked on flying inverted pendulum platforms, quadrotor-based systems, and trajectory generation methods for aggressive maneuvers.
My broader goal is to develop control and planning methods that remain practical beyond simulation, especially when models are imperfect, actuation is limited, and experiments must work on physical platforms.
News
- 2025.12: Our manuscript titled Trajectory Generation and Extended High-Gain Observers Based Output Feedback Control for an Underactuated Flying Inverted Pendulum has been accepted for publication in IEEE TASE.
- 2025.11: Joined the National University of Singapore as a Research Fellow.
- 2025.10: Successfully obtained my Ph.D. degree from the University of Macau.
- Service: Reviewer for IEEE TASE, IEEE RA-L, Control Engineering Practice, and IEEE TSMC: Systems.
Research
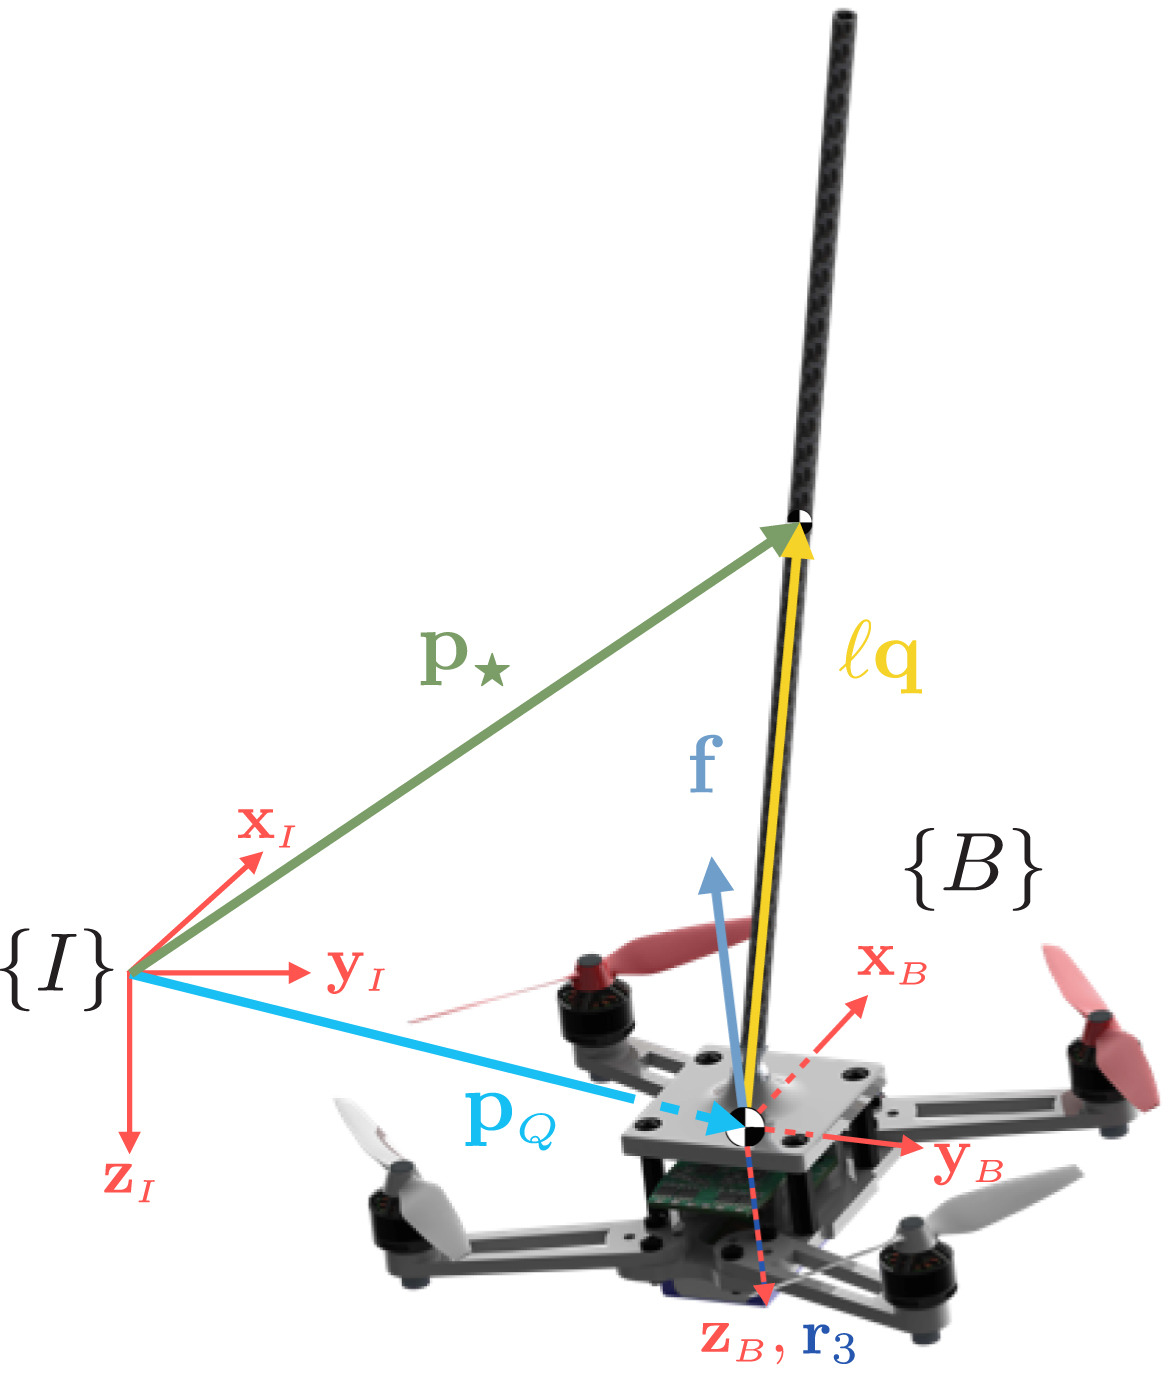
01 Robust nonlinear 3D control of an inverted pendulum balanced on a quadrotor
Automatica, 2024
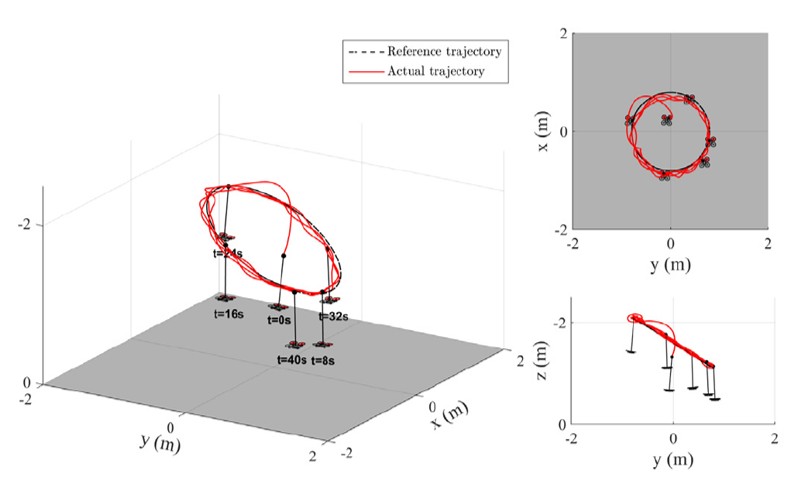
This work studies full three-dimensional trajectory tracking for a flying inverted pendulum balanced on a quadrotor under unknown constant disturbances. Instead of relying on linearization, it develops a robust nonlinear control strategy that coordinates pendulum translation, pendulum direction, and quadrotor attitude in a unified framework. The paper shows that the proposed controller can achieve asymptotic tracking while preserving upright balance in a highly coupled underactuated aerial system.
02 Output feedback control of an underactuated flying inverted pendulum
Control Engineering Practice, 2025
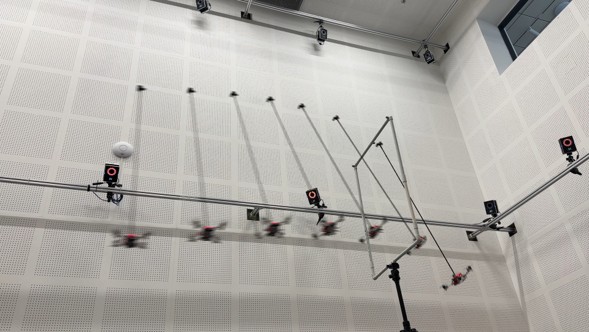
This paper tackles trajectory tracking for an underactuated flying inverted pendulum when direct measurements of all state variables are not available and constant external disturbances are present. A uniformly completely observable linear time-varying model is introduced, and a Kalman filter is used to estimate angular velocity, disturbances, and noise-filtered pendulum orientation measurements. These estimates are then embedded in a nonlinear backstepping output-feedback controller, with both simulations and experiments validating the resulting tracking performance.
03 Trajectory Generation and Extended High-Gain Observers Based Output Feedback Control for an Underactuated Flying Inverted Pendulum
IEEE Transactions on Automation Science and Engineering, 2025
This paper presents integrated trajectory generation and output-feedback control strategies for an underactuated flying inverted pendulum operating under unknown time-varying disturbances. It introduces two extended high-gain observers to independently estimate the pendulum's linear and angular velocities, as well as the unknown disturbances, and embeds them within a nonlinear hierarchical Lyapunov-based control framework. By exploiting the differential flatness of the system, the work also develops a trajectory generation method for aggressive window-crossing maneuvers, with both simulations and experiments validating the agility, robustness, and precision of the proposed approach.
Invited Talks
- 2025.10.26: Oral talk at Workshop on Advanced Aerial Robotics, University of Tokyo.
- 2022: Oral talk at the 41st Chinese Control Conference (CCC).
Visitors
Visitor Locations